ON-DEMAND FIELD SERVICE / PALM-01

Palmion

SYSTEM READY 00:00:00
◒
29°CClear field conditions
AUTONOMOUS FIELD MAP

Plantation block A-12 · 1,000 palms · 18.6 ha

water + 4 m buffercliff +0.8-1.2 mlaneACOswarmfleet
GPS LOCKED·MAX GRADE 11 DEG·WATER BUFFER 4 M·RTK ±2 CM
ROUTE: COMPARISON READYSECTOR N-01
CURRENT TARGETAwaiting dispatchACO score: 0.00
IDLE
N NORTH50 mClick a palm to inspect its fused prediction
MISSION OUTCOME · ALL UNITS DOCKEDPriority sweep complete
DRONE SURVEY · REAL—
LANE ETA · REAL—
ACO ETA · REAL—
SWARM ETA · REAL—
TIME SAVED VS LANE—
GROUND FLEET ALGORITHM Choose the route shown on the map and executed by the bot fleet.
LIVE DRONE ACTIVITYAerial units armed
LIVE BOT ACTIVITYBots awaiting drone survey
OPERATING ASSUMPTIONS 8 kWh LFP pack / 4 h nominal cruise duty Navigation, stereo, acoustic sensing, and thermal sensing are modeled at a 2 kW average cruise load. Cold-plasma operation is modeled at 2.5 kW total.
FIELD CHARGING 20% reserve → 100% in 27 simulated min An 18 kW caravan DC charger supplies 3 percentage points per simulated minute after thermal taper. Returns are energy-triggered, not a fixed every-three-hour stop.
ETA ACCOUNTING Transit + validation + plasma + charging Every ETA includes the measured route distance, terrain, one-minute validation, 20-minute cold-plasma cycle, reserve returns, and charge rotations.
FLEET BATTERY / 4 H NOMINALIDLE
ACTIVE SENSOR LAYERREADY
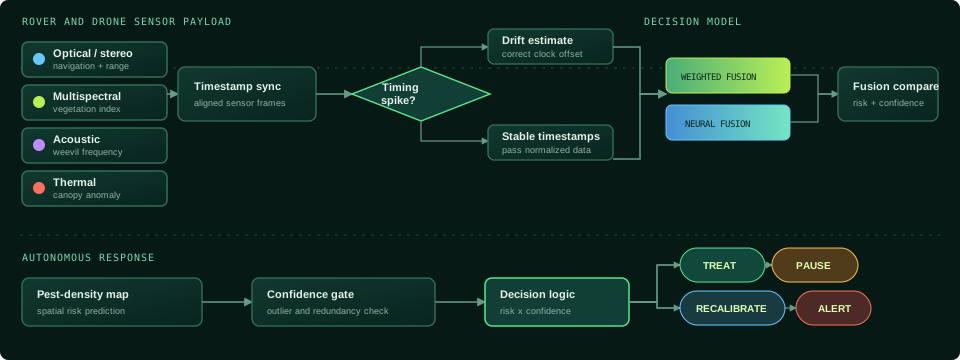
HYBRID SENSOR FUSION

From rover sensor payload to treatment decision
LIVE MODEL
Diagram of optical stereo, multispectral, acoustic, and thermal sensor signals passing through timestamp synchronization, drift correction, weighted and neural fusion, confidence and risk prediction, and autonomous treatment decisions.